
PEARL at TU Darmstadt
Robot learning for
intelligent assistance.
We develop robots that perceive, learn, and act through interaction. Our research connects mobile manipulation, dexterous and bimanual skills, and structured embodied intelligence.
Move
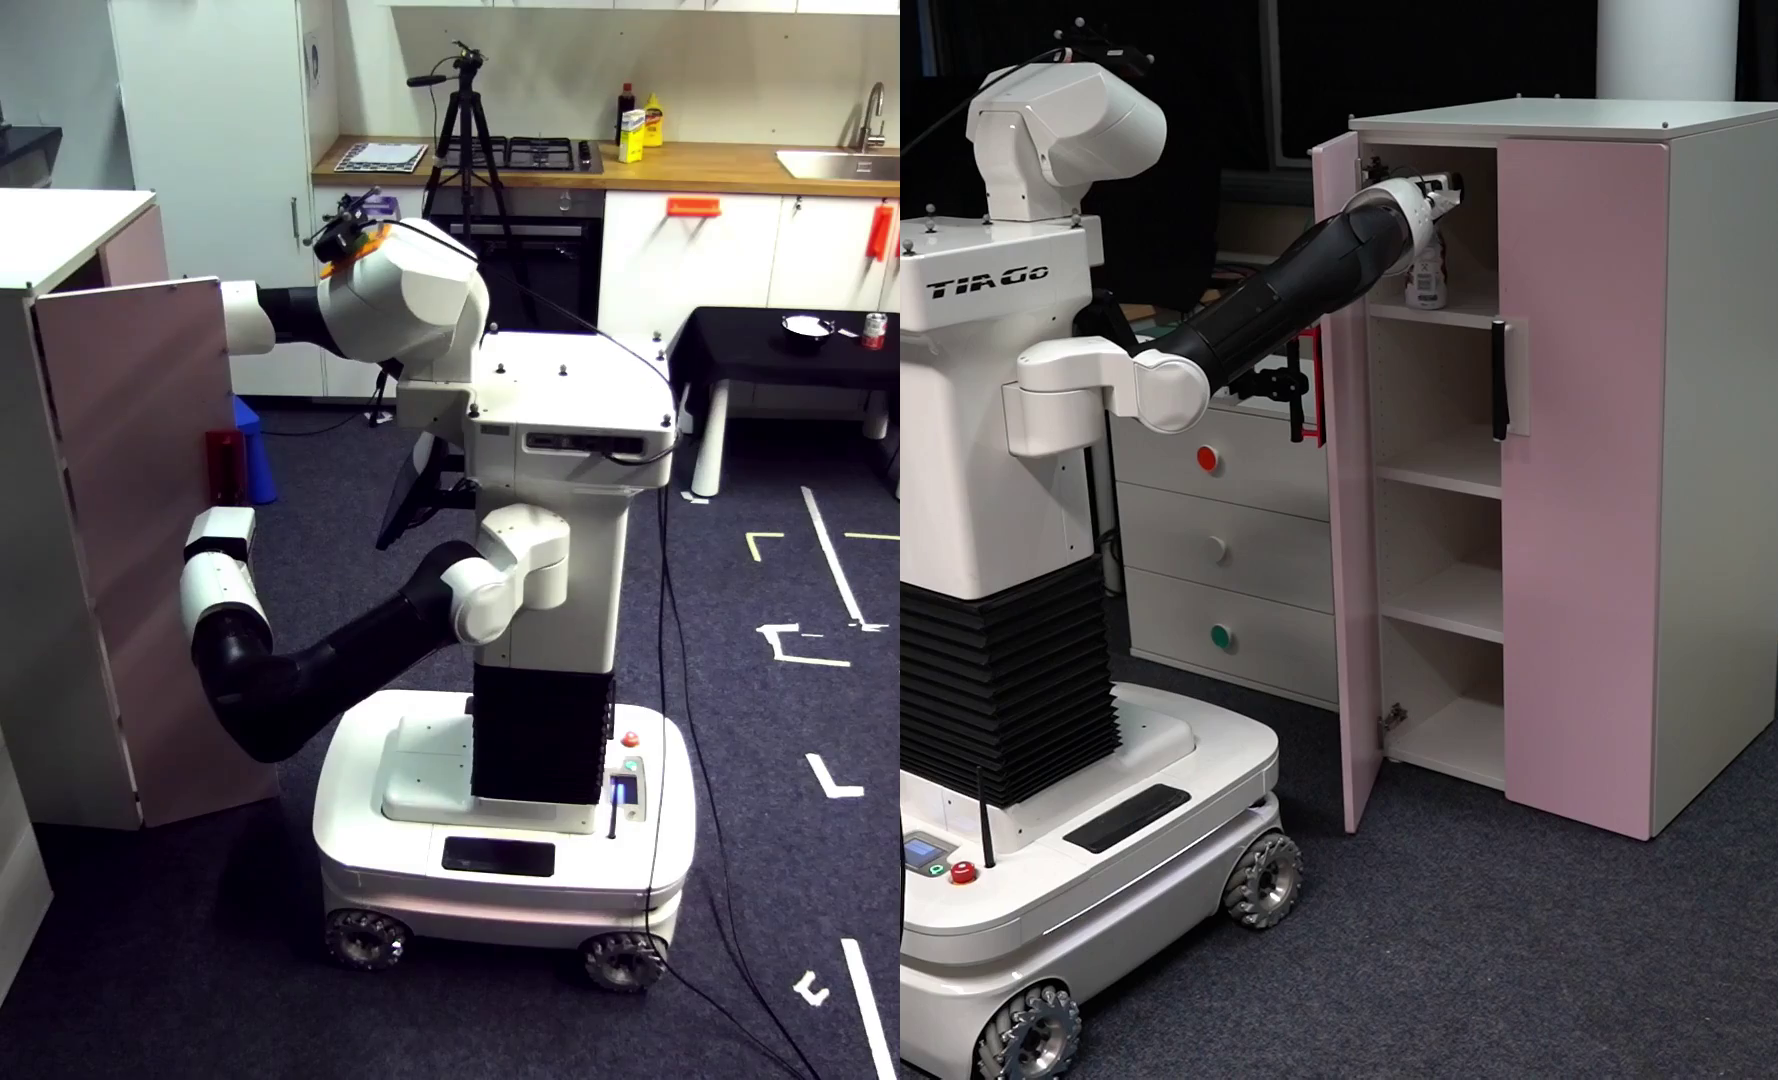
Mobile manipulation
Learning to coordinate mobility and manipulation for everyday environments.
Interact
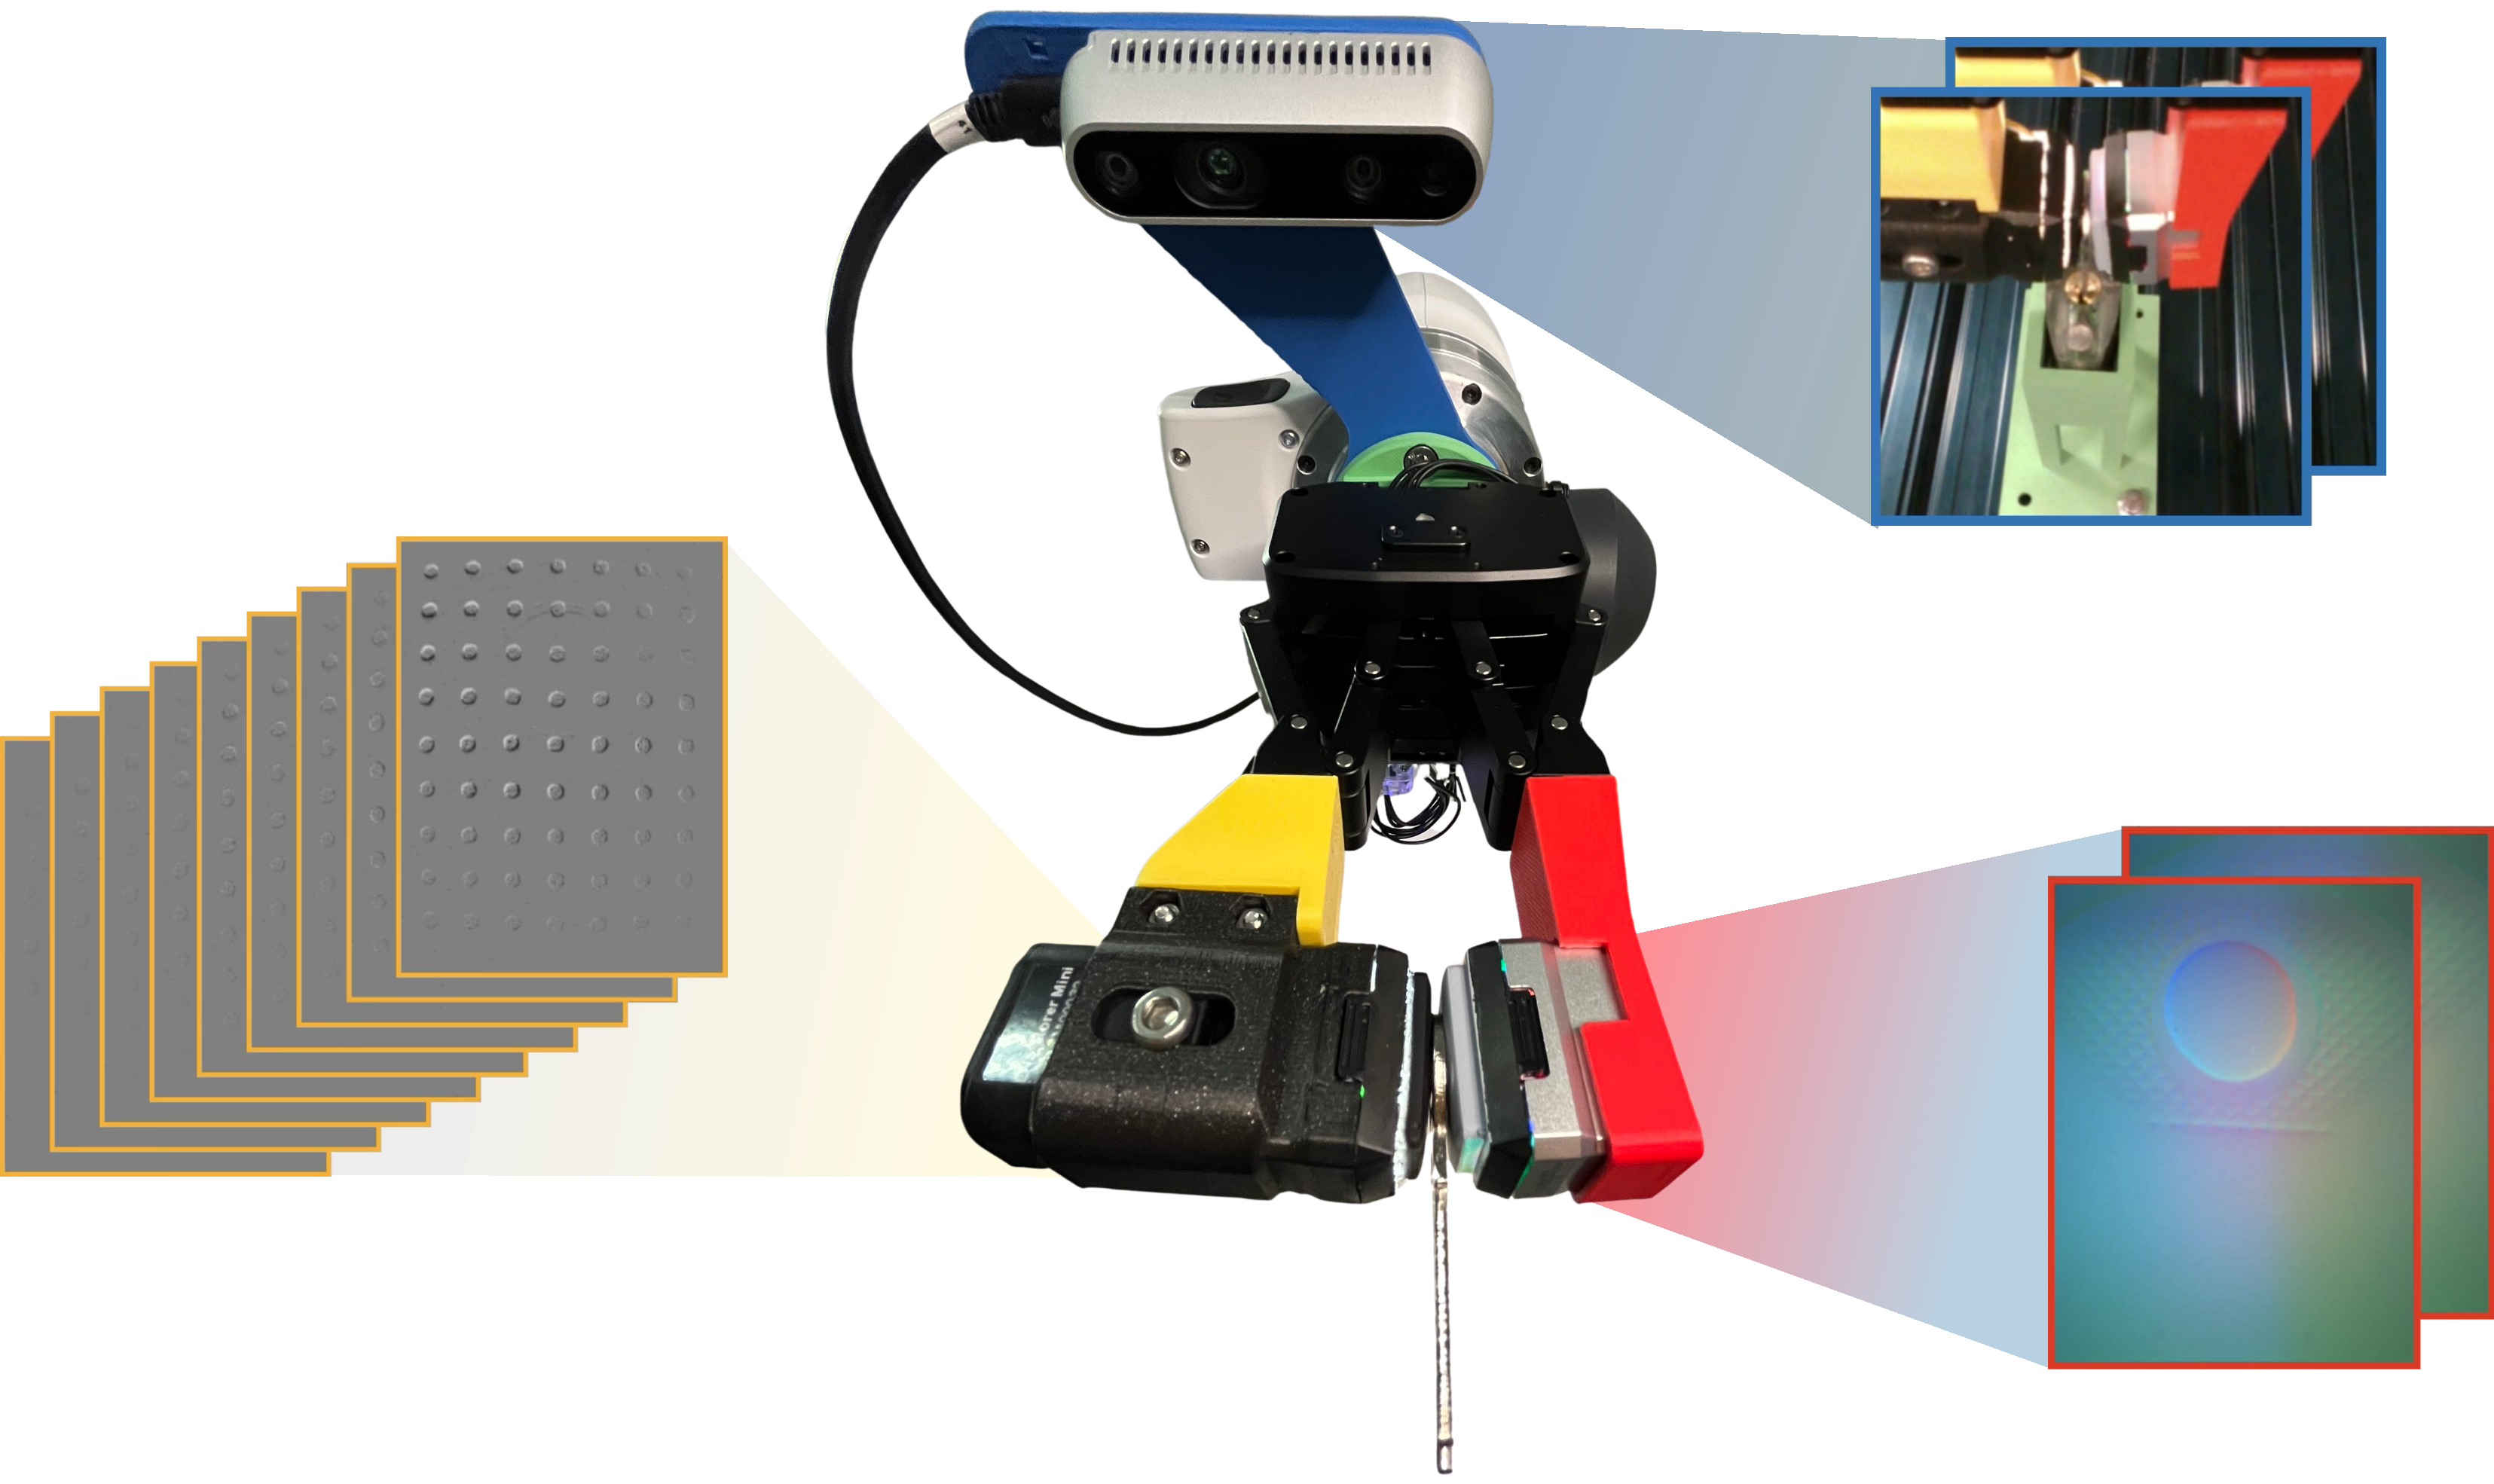
Dexterity and contact
Learning manipulation skills through touch, demonstrations, and bimanual coordination.
Understand
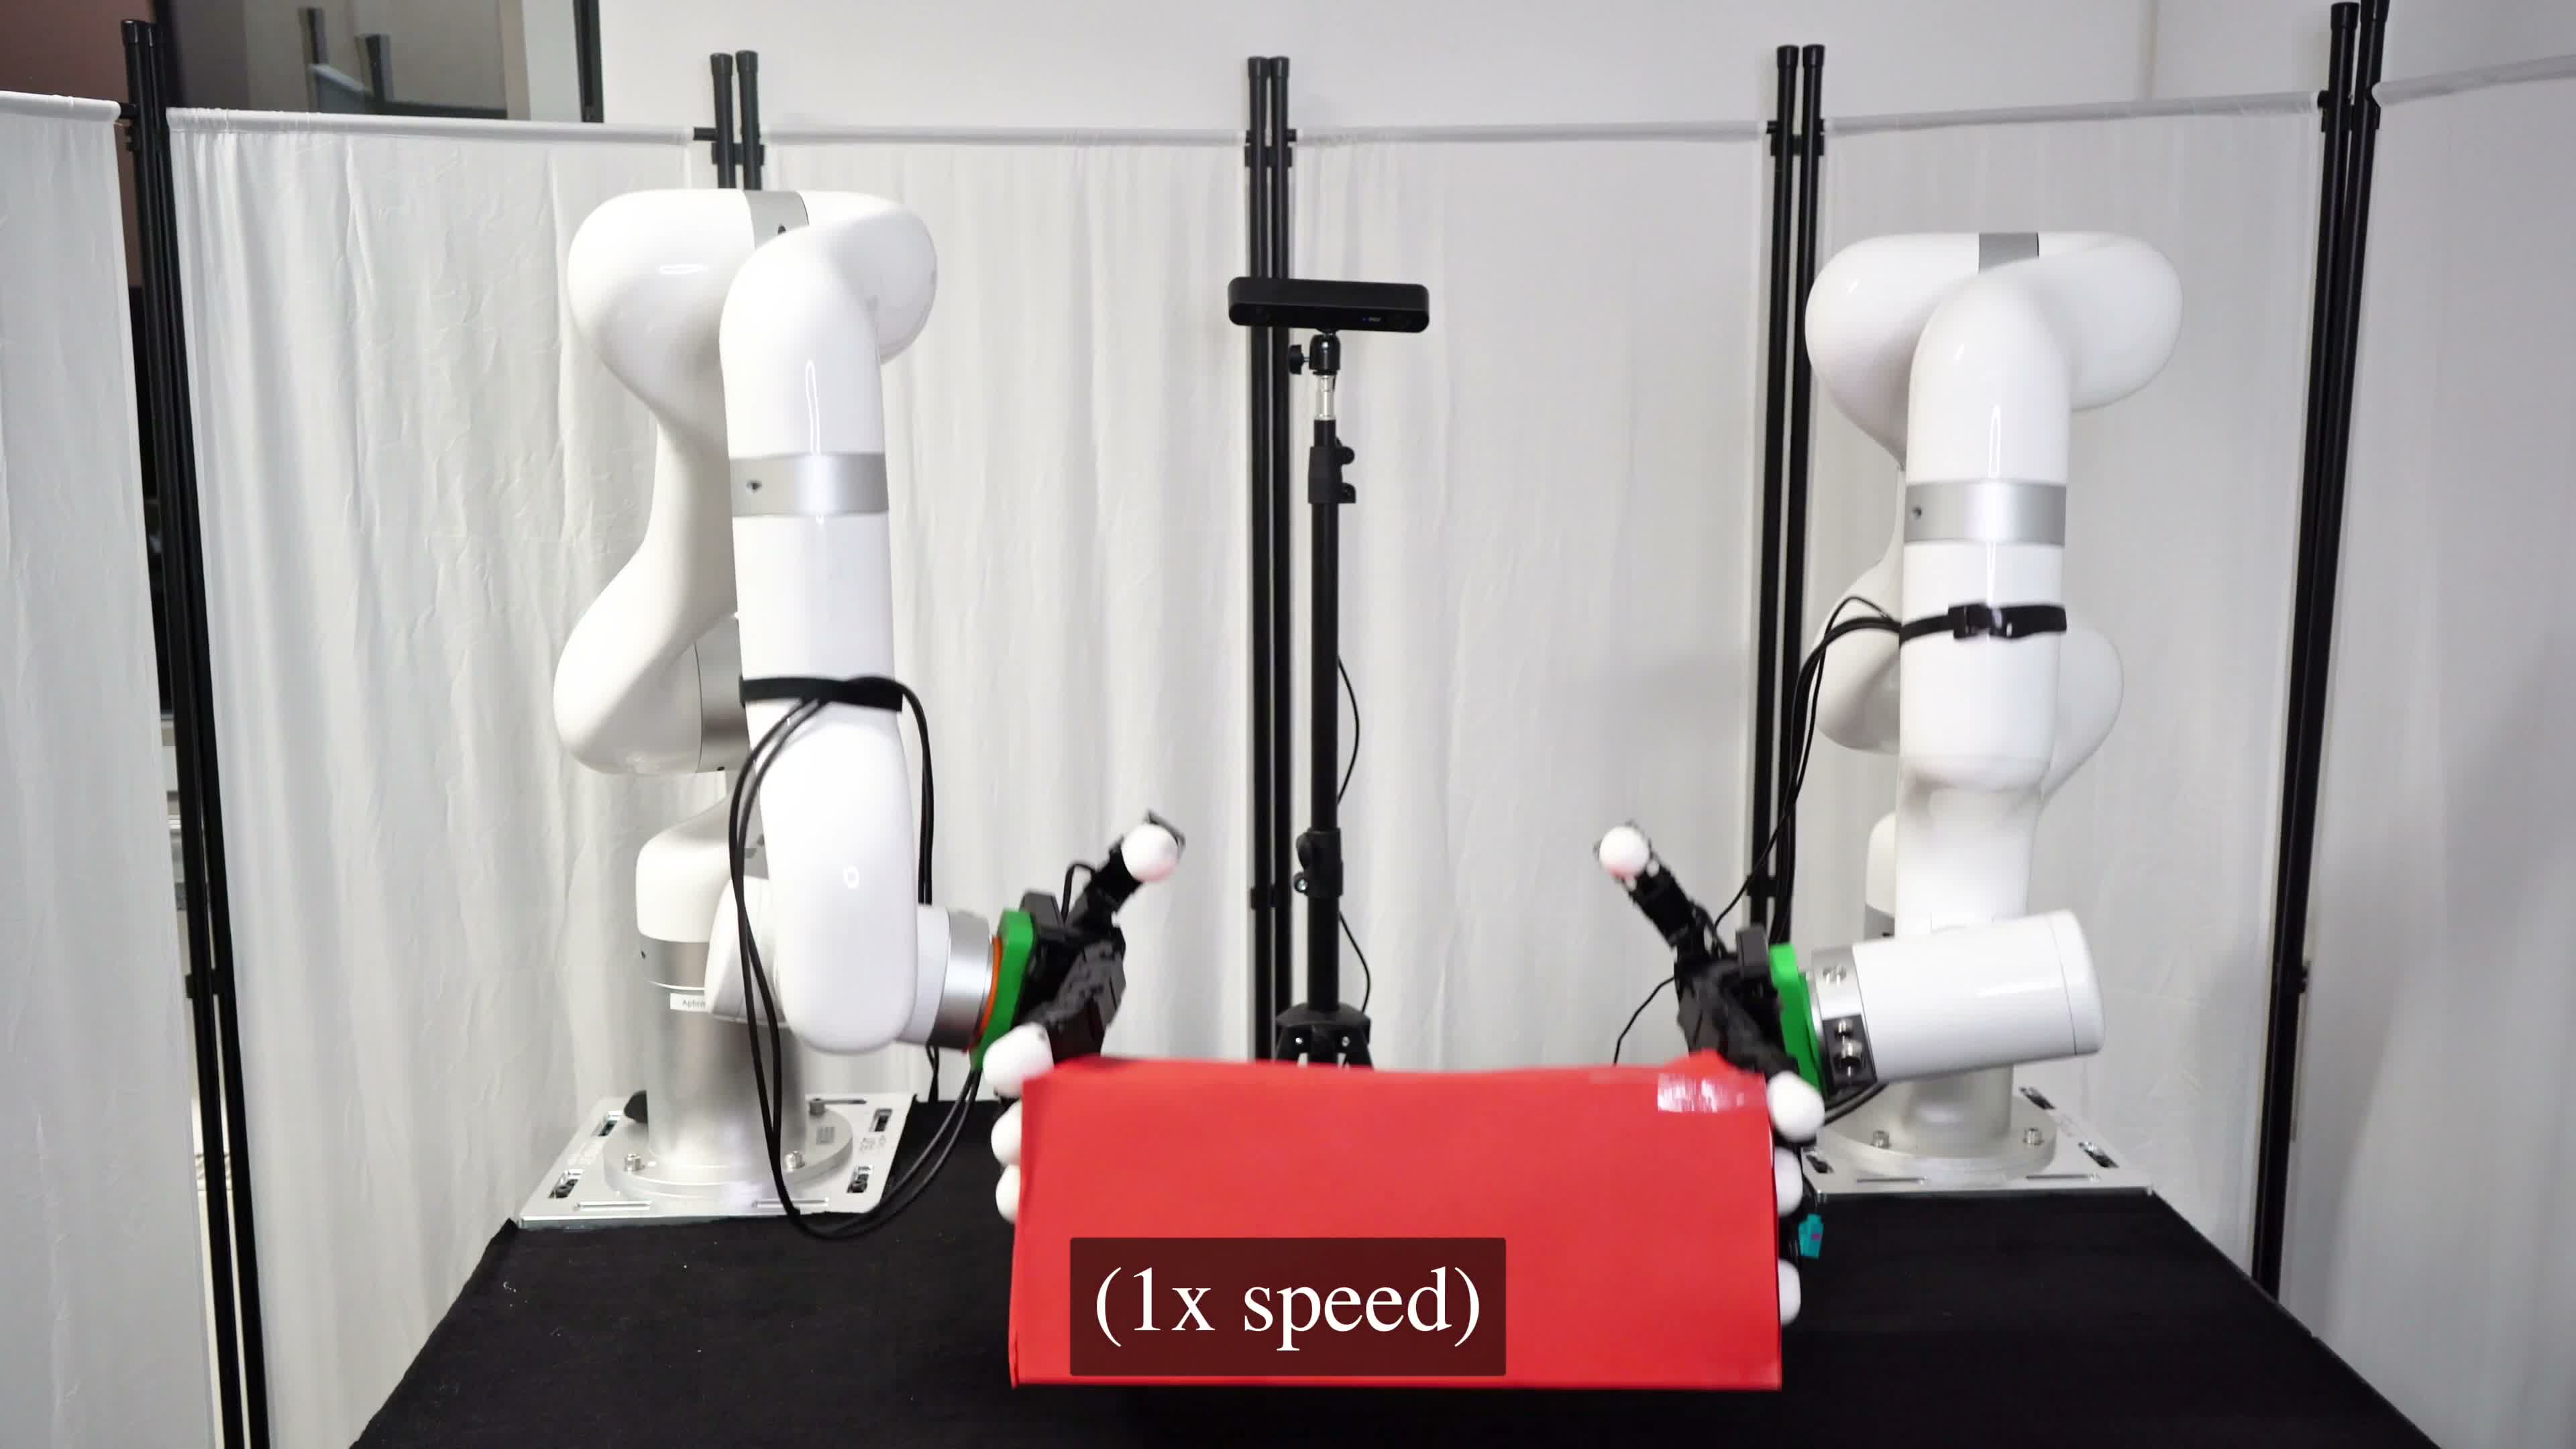
Embodied intelligence
Structured representations and learning from interaction for perception, planning, and control.
Latest from PEARL
-
PEARL at CoRL 2026: papers, demonstrations and workshops
Five accepted papers, one oral presentation, two invited workshop talks, MiTaS demonstrations, PolyUMI at the UMI Arena, and two postdoctoral opportunities. Meet…
-
Paper accepted @ RA-L
Semantic-Geometric Task Representations for Bimanual Manipulation from Human Demonstrations to Robot Action Planning Franziska Herbert, Vignesh Prasad, Han Liu, Dorothea Koert, Georgia…
-
New Paper accepted @ RA-L!
Self-Supervised Multisensory Pretraining for Contact-Rich Robot Reinforcement LearningRickmer Krohn, Vignesh Prasad, Gabriele Tiboni, Georgia Chalvatzaki TLDR: Multisensory pretraining enhances RL for contact-rich…
JOIN PEARL
Two postdoctoral positions
Learning for control of dexterous, contact-rich manipulation, and structured and interactive embodied intelligence.


Stay connected
Subscribe to news from our lab.